01 / See
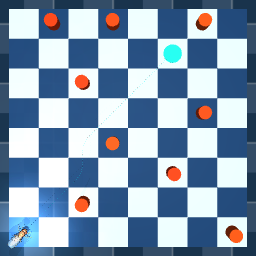
A trained camera model turns rendered pixels into occupied squares.
Can a neural navigator steer a physically simulated fly across a chessboard? Watch the verified run.
Embodied intelligence is easier to understand when its jobs are separated and inspectable.
A trained camera model turns rendered pixels into occupied squares.
The trained navigator turns the board, start, and target into one of eight directions.
A published FlyBody controller turns that direction into joint and adhesion control.
This board runs the saved navigation network in your browser. The default A1 → F7 route is the command used in the physical simulation above.
Choose a destination step 00